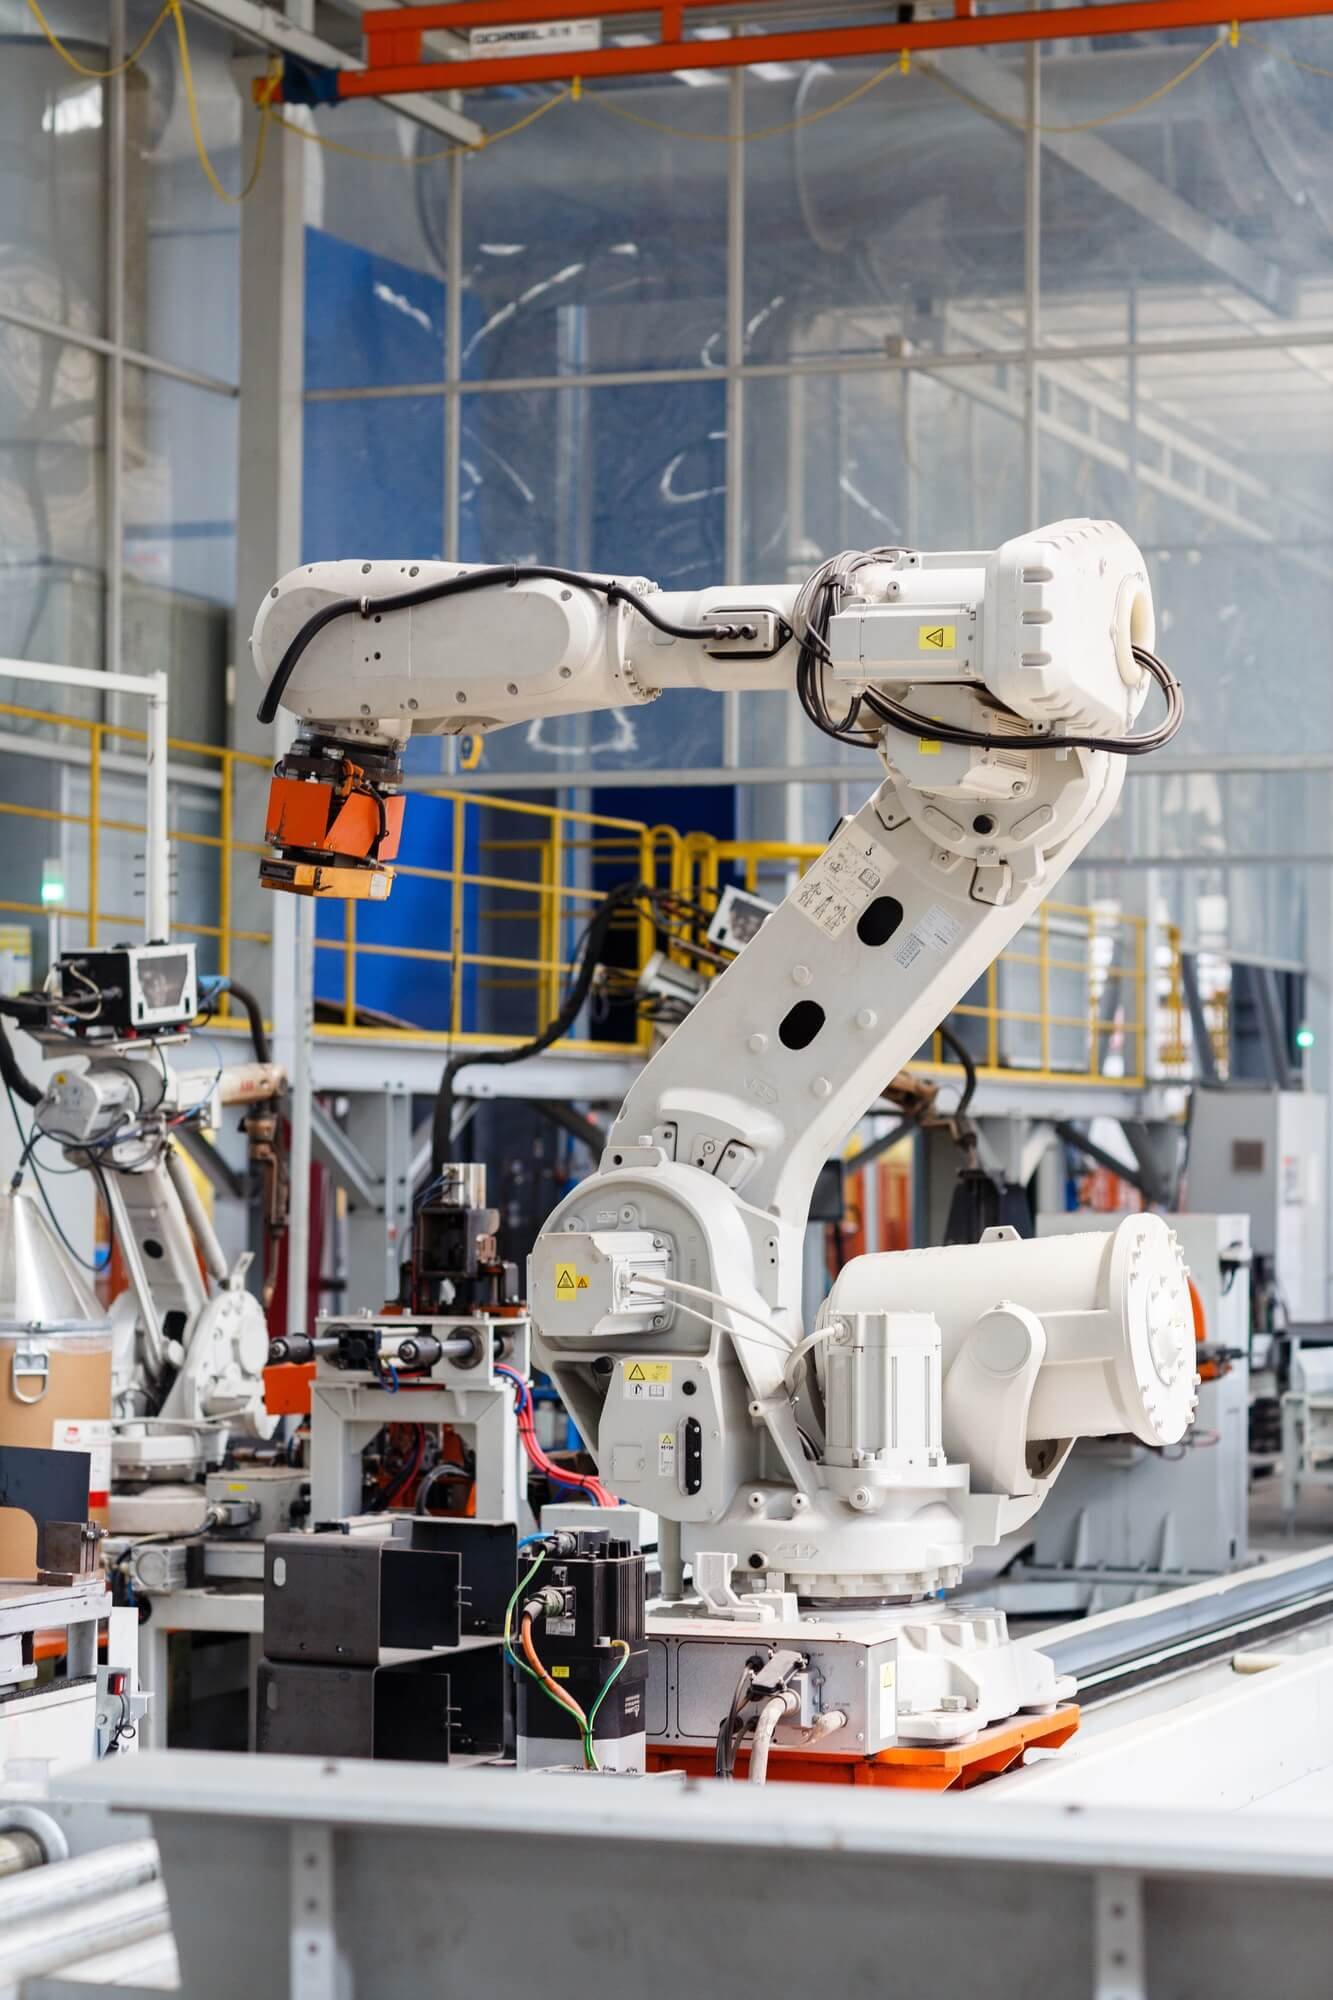
Many buyers fear the wrong robot. They see clean demos. They miss dirty weld seams, heat distortion, and hard-to-reach joints. **A welding robot must solve three real problems: path planning, process matching, and end reachability. If it cannot find the seam, choose the right welding process,…
Many factories feel pressure from unstable weld quality, rising labor cost, and delayed delivery. I see the same problem become bigger when buyers choose the wrong robot. **I choose an intelligent welding robot by checking its real working logic, not only its price. I first separate…
I have seen many factories lose time at the robot teaching stage. The pain looks small at first, but it soon blocks delivery, quality, and profit. **Yes, construction machinery welding can move beyond complex teaching by using programming-free welding robots with 3D vision scanning and automatic…
I have seen one small calibration mistake turn a good welding cell into a rework job. The risk grows fast when nobody checks the points. **I use 60-point link length calibration to reduce trajectory mismatch between the robot system and the external axis. I treat it…
# 60-Point Link Length Calibration Operation Guide ## 1. Purpose of Calibration The 60-point link length calibration is mainly used to correct the geometric relationship between the robot system and the external axis, ensuring that the robot’s trajectory coordinates remain consistent with the actual mechanical position…