
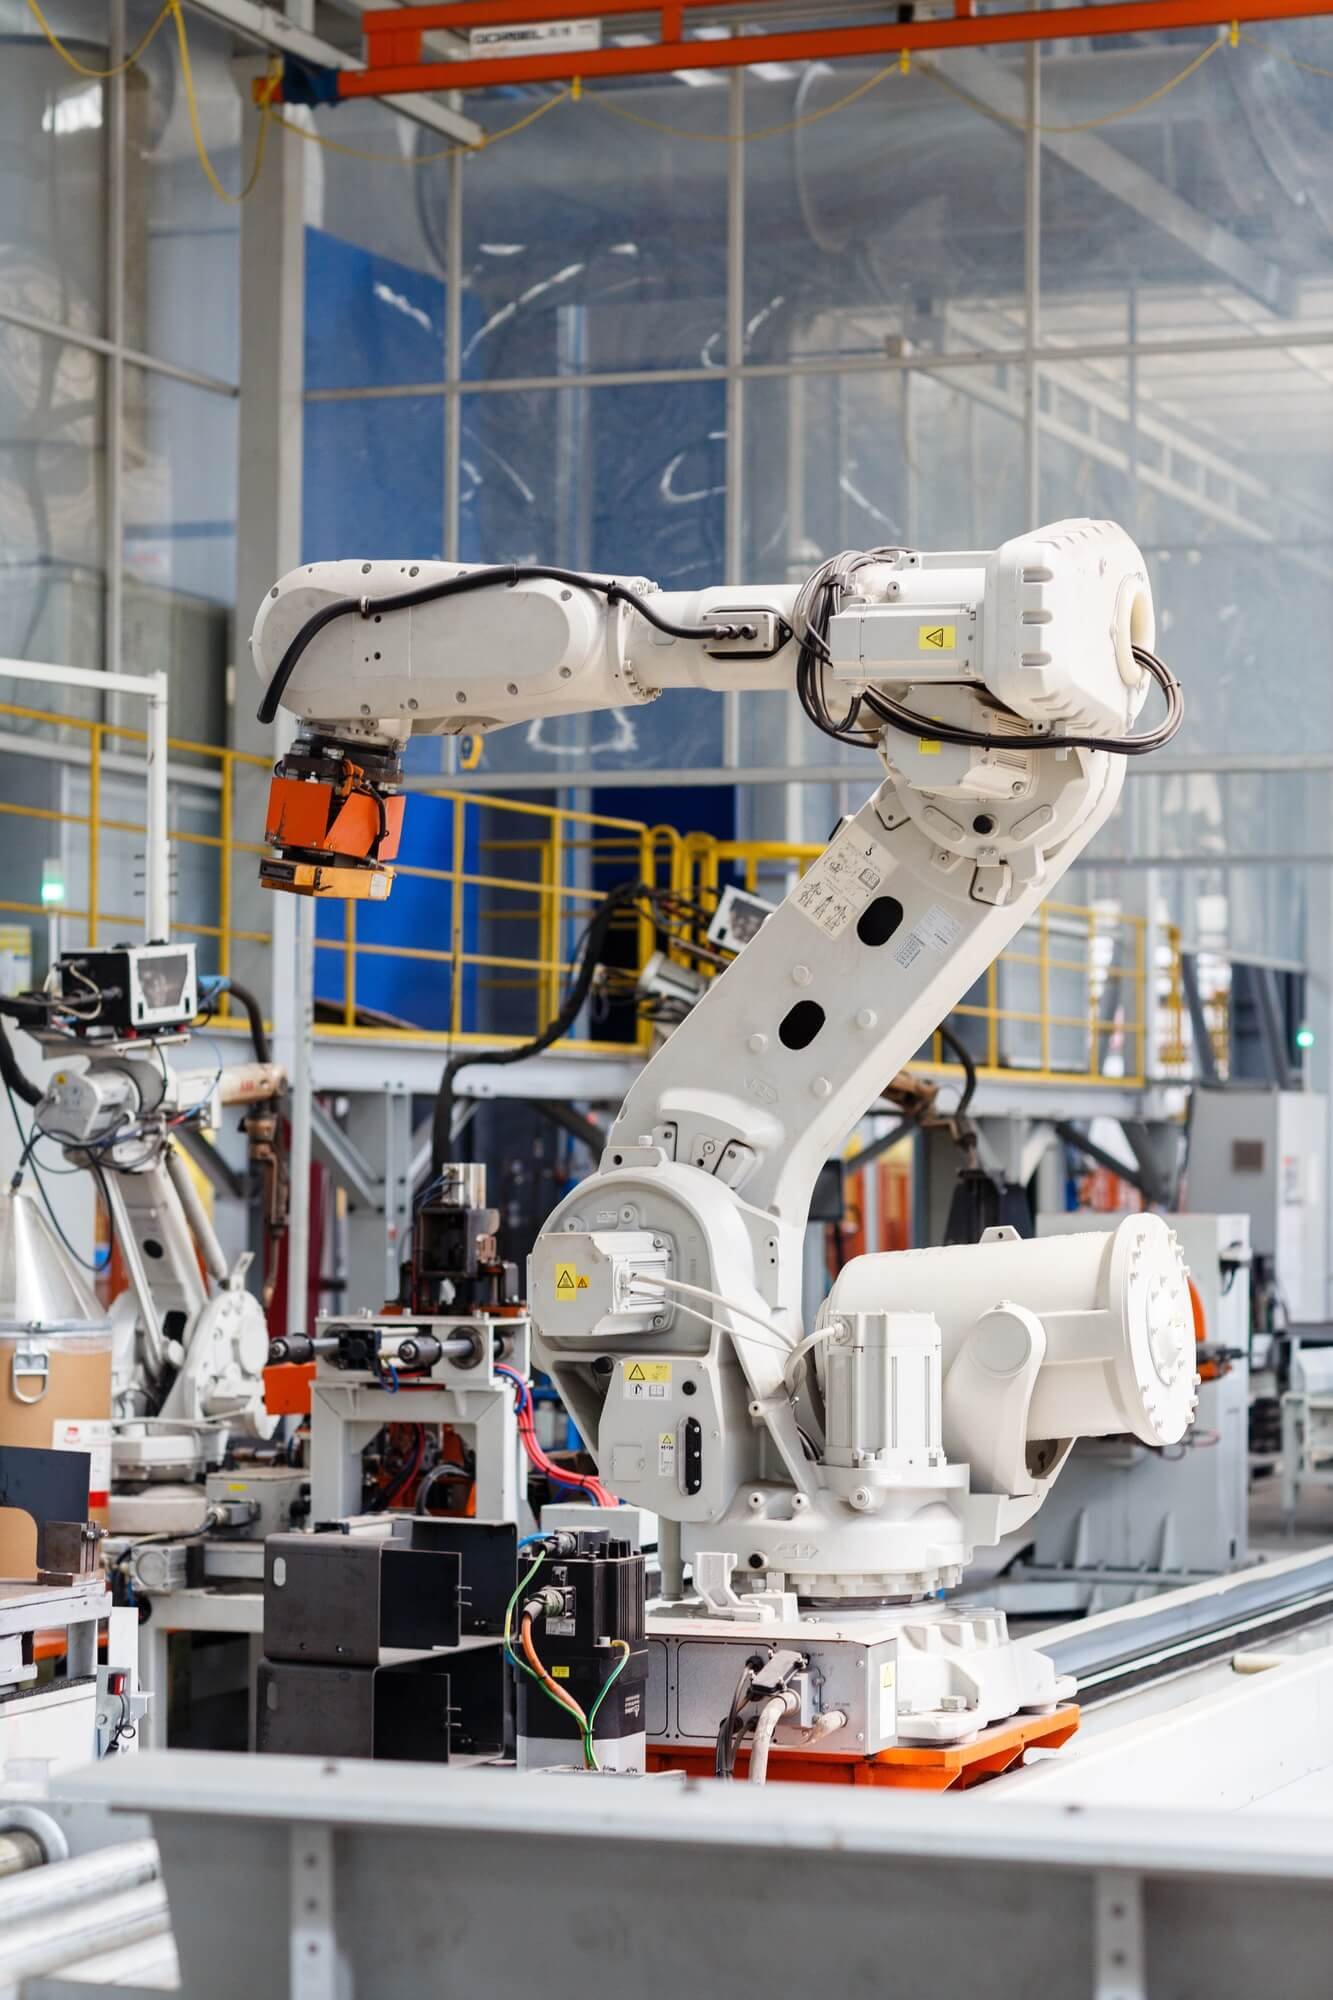
Elfin Collaborative Robot
A 6-DOF cobot with a dual-joint module design, exported to more than 100 countries for assembly, picking, welding, grinding and spraying.
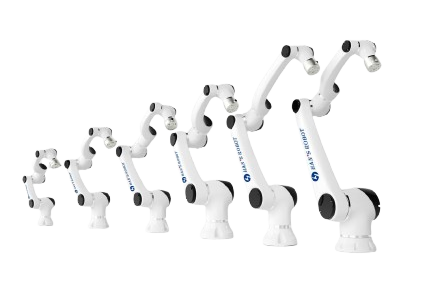
Elfin Collaborative Robot
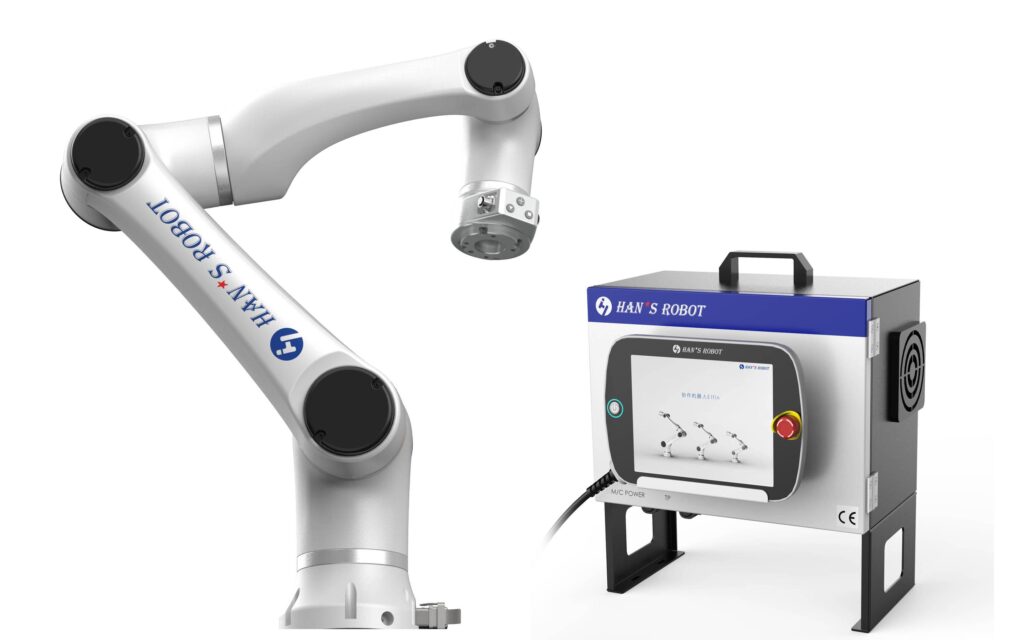
The Elfin collaborative robot can be used in automated integrated production lines, assembly, picking, welding, grinding, spraying and other applications, and has been exported to more than 100 countries and regions. It adopts a unique double-joint module design, where one motion module contains two joints to form a unique kinematic structure, which not only differs from most collaborative robots on the market, but also provides more flexibility when working.
- First Dual-joint Module Design In China
- Optimized singularity
- Highly Flexible 6-DOF Collaborative Robot
- Modularity
Configuration Details
| Configuration Instructions | Robot | Control Box | Teach Pendant | Cable | Applications |
|---|---|---|---|---|---|
| Standard |  |
Standard control box | Standard teach pendant (Resolution 1024*600, screen size: 10.4 inches) | 5m | / |
| Mini control box | |
Mini control box (Power module:Optional) | Tablet teach pendant (Optional) | 5m | Applied for automation equipment, AGV, mobile robots, etc. |
Standard Control Box Specifications Table
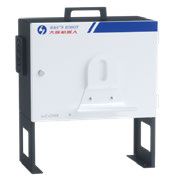
| Attribute | Details |
|---|---|
| Dimensions | 445.2mm x 318.8mm x (360+176)mm |
| Stand Height | 176mm |
| Weight | 18.5kg |
| Power Output | 48V DC |
| Working Temperature | 0~50℃ |
| Working Humidity | 90% relative humidity (non-condensing) |
| IP Classification | IP20 |
Mini Control Box (Optional)
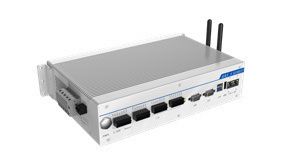
| Attribute | Details |
|---|---|
| Dimensions | 323x221x80(mm) |
| Power Input | DC30~60V |
| I/O Source | DC24V |
| I/O Port | Inputs 8, Outputs 8 |
| IP Classification | IP20 |
| Communication | TCP/IP Modbus |
Teach Pendant Specifications Table
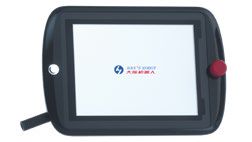
| Attribute | Details |
|---|---|
| Dimensions | 327 mm x 230 mm x (45+22) mm |
| Weight | 2.7kg (including cable) |
| Display | 10.4” |
| Resolution | 1024 x 800 |
| E-stop Button | 1 |
| IP Classification | IP54 |
Technical Specification
Model E03, E05, E05-L, E10, E10-L, E15
Scroll the table horizontally to see every column.
| Model | Weight | Payload | Reach | Joint Range | Repeatability | Power Consumption | Joint Speed | Tool Speed | Degree of Freedom | Control Box I/O | Communication | IP Classification |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| E03 | 18kg | 3kg | 590mm | J1, J4, J6: ±360°; J2: ±135°; J3: ±150°; J5: ±147° | ±0.02mm | 100W (typical) | J1-J4: 180°/s; J5-J6: 200°/s | 2m/s | 6 | 16 Digital I/O, 2 Analog I/O | TCP/IP, ModbusTCP | IP54 (optional IP66) |
| E05 | 25kg | 5kg | 800mm | J1, J4, J6: ±360°; J2: ±135°; J3: ±150°; J5: ±147° | ±0.02mm | 180W | J1-J4: 180°/s; J5-J6: 200°/s | 3m/s | 6 | 16 Digital I/O, 2 Analog I/O | TCP/IP, ModbusTCP | IP54 (optional IP66) |
| E05-L | 26kg | 3.5kg | 950mm | J1, J4, J6: ±360°; J2: ±135°; J3: ±150°; J5: ±147° | ±0.02mm | 180W | J1-J4: 180°/s; J5-J6: 200°/s | 3m/s | 6 | 16 Digital I/O, 2 Analog I/O | TCP/IP, ModbusTCP | IP54 (optional IP66) |
| E10 | 43kg | 10kg | 1000mm | J1-J2: 100°/s; J3-J4: 150°/s; J5-J6: 180°/s | ±0.03mm | 350W | J1-J2: 100°/s; J3-J4: 150°/s; J5-J6: 180°/s | 2m/s | 6 | 16 Digital I/O, 2 Analog I/O | TCP/IP, ModbusTCP | IP54 (optional IP66) |
| E10-L | 45kg | 8kg | 1300mm | J1-J2: 100°/s; J3-J4: 150°/s; J5-J6: 180°/s | ±0.03mm | 350W | J1-J2: 100°/s; J3-J4: 150°/s; J5-J6: 180°/s | 2.5m/s | 6 | 16 Digital I/O, 2 Analog I/O | TCP/IP, ModbusTCP | IP54 (optional IP66) |
| E15 | 60kg | 15kg | 1300mm | J1-J2: 80°/s; J3-J4: 120°/s; J5-J6: 150°/s | ±0.05mm | 600W | J1-J2: 80°/s; J3-J4: 120°/s; J5-J6: 150°/s | 2m/s | 6 | 16 Digital I/O, 2 Analog I/O | TCP/IP, ModbusTCP | IP54 (optional IP66) |
Safety and Compliance Standards
Elfin cobots include various in-built safety features, designed in compliance with international standards like ISO 10218 and EN ISO13849-1:2008. The safety functions are pre-configured but can be adjusted according to operational needs.
Built-In Safety Devices
Includes both digital and analog I/O safety devices, along with emergency stop and power cut-off functions.
Emergency Stop and Collision Detection
Emergency stops on both the control box and teach pendant enable immediate halts during danger, while collision detection prevents accidents by stopping movement when external force exceeds preset limits.
IP Classification and Environment Suitability
Elfin robots are IP54 rated, with options for IP66, making them resistant to dust and humidity. Not intended for explosive or flammable environments.
Safety Light Curtains and Limit Controls
Light curtains and joint limits help establish safe operational zones, reducing potential risk to operators.
Safety Precautions Table
| Safety Level | Description | Outcome |
|---|---|---|
 Danger |
Non-compliance may lead to death or serious injury | Always ensure safety configuration matches application needs |
 Warning |
Risk of injury or equipment damage | Ensure all safety devices and settings are engaged correctly |
 Caution |
May result in equipment malfunction | Avoid improper handling and unauthorized modifications |
Emergency and Collision Protection
Elfin cobots include emergency stop buttons on both the control box and the teach pendant, as well as collision detection sensors that stop movement when excess force is detected. Additional safety measures include:
- Safe Zones and Limit Controls: Configurable safe zones, joint limits, and safety light curtains.
- Force Limitation: Automatically stops the cobot if excessive force is detected, ensuring the safety of operators in collaborative environments.
Software Interface: Han’s Robot Demonstrator
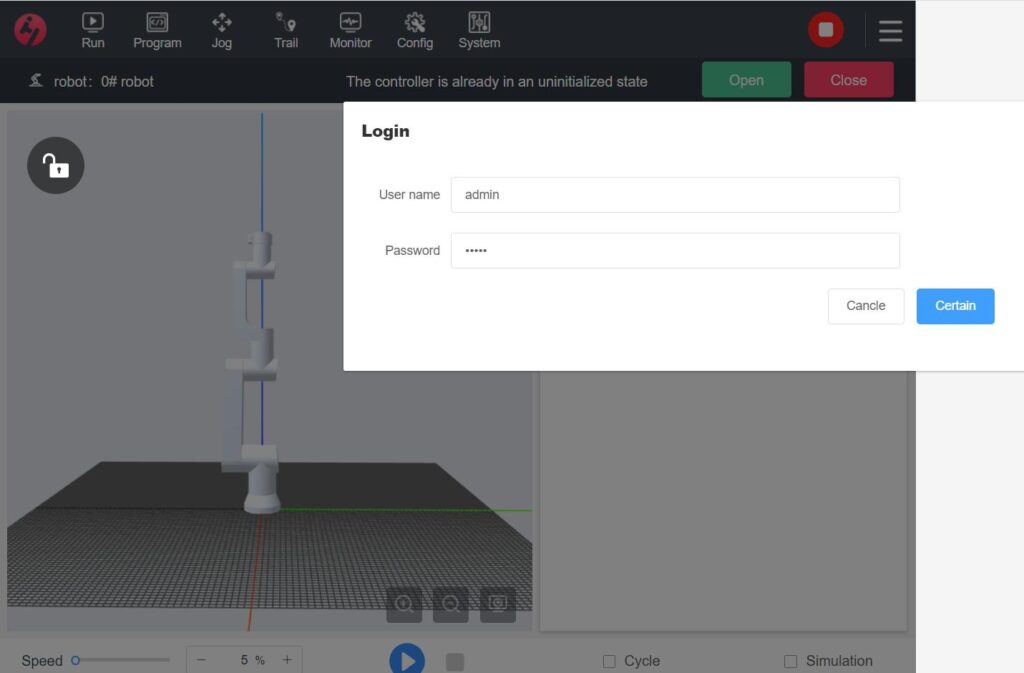
Elfin cobots are operated through the intuitive Han’s Robot Demonstrator software, which allows for programming, monitoring, configuration, and management from a single interface:
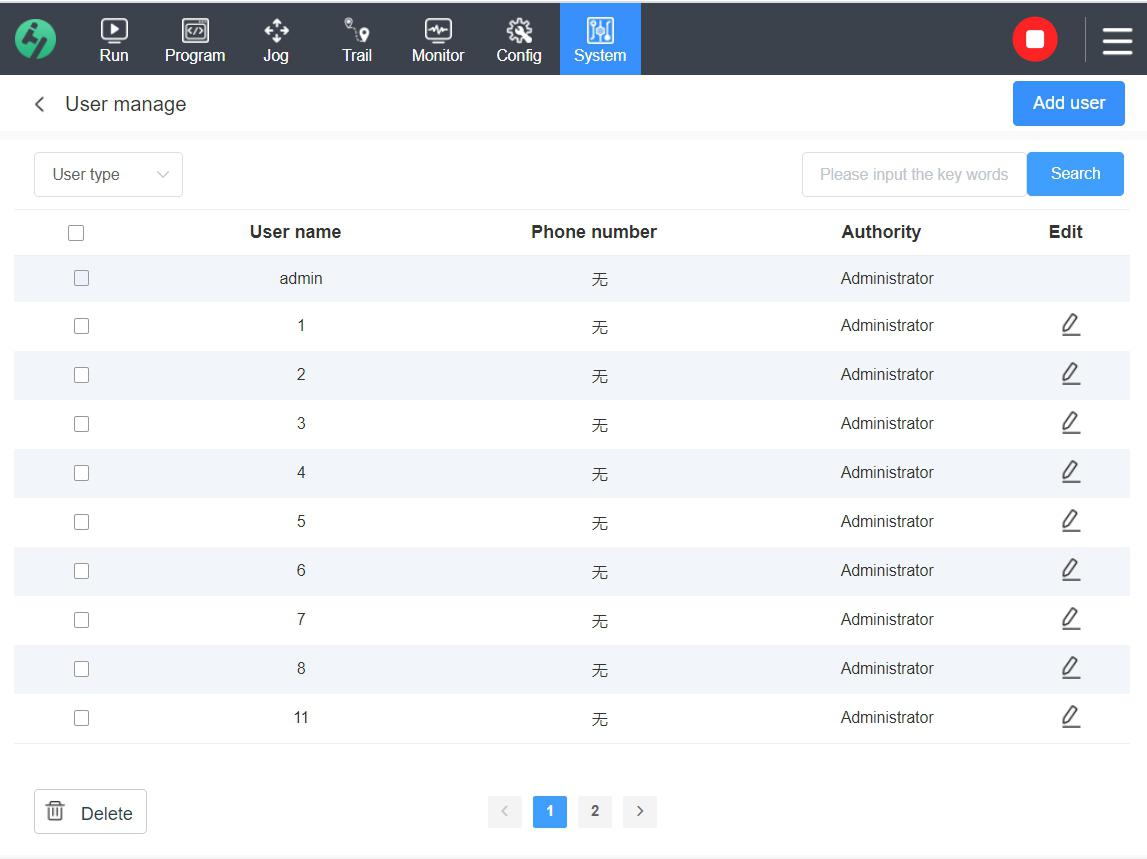
- User Roles and Permissions: Supports Administrator, Operator, and Visitor roles, with customizable permissions based on security requirements.
-
Visual Interface Elements:
- 3D Model Visualization: Provides a real-time view of the robot’s positioning and movement.
- LED Status Indicators: Colors indicate various robot states (e.g., green for enabled, red for error) for quick status recognition.
- Status Descriptions and Error Prompts: Error prompts notify users of issues such as joint errors or connection issues for swift troubleshooting.
- Multi-Language Support and Accessibility: Allows for language selection, making the interface accessible globally.
| User Permissions Table | |
|---|---|
| User Role | Access Rights |
| Administrator | Full access to all robot functions, including programming and configuration |
| Operator | Access to operation, inching (excluding point saving), and monitoring functions |
| Visitor | Limited to inching operations only, no programming or configuration access |
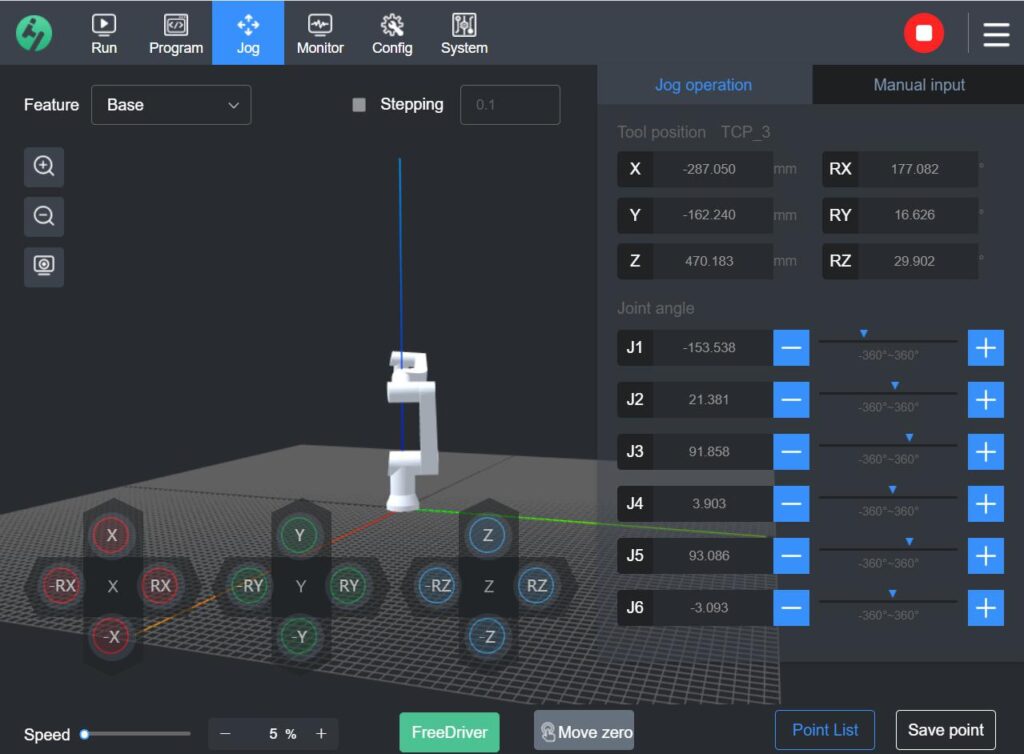
| Main Interface Elements | |
 Run |
For robot startup and executing programs. |
 Programming |
Create, modify, and manage robot scripts. |
 Monitoring |
Observe I/O states, body status, and logs in real-time. |
 Configuration |
Set robot parameters (TCP, installation angle, user coordinates). |
 Management |
Manage user accounts and update the system. |
 Inching |
Manually adjust robot posture and position. |
Manual Control and Configuration
Elfin cobots offer precise manual positioning, with settings for configuring tools, movement, and payload:
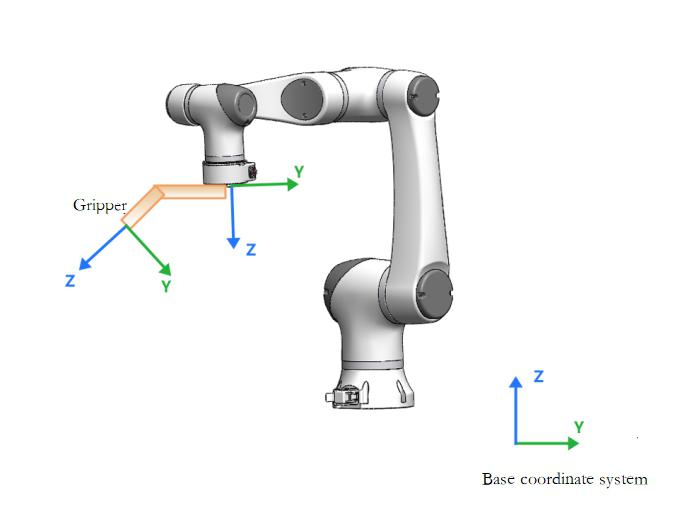
- Coordinate System Options: Operate in base, user, or tool coordinates for tailored control over robot movement.
- Speed Bar and Fine Adjustment: Adjustable speed control and fine-tuning options allow for precise movements in increments as small as 0.1mm, ideal for sensitive tasks.
- Zero-Force Demonstration Mode: Allows the robot to be manually guided without resistance, helping operators accurately position it.
-
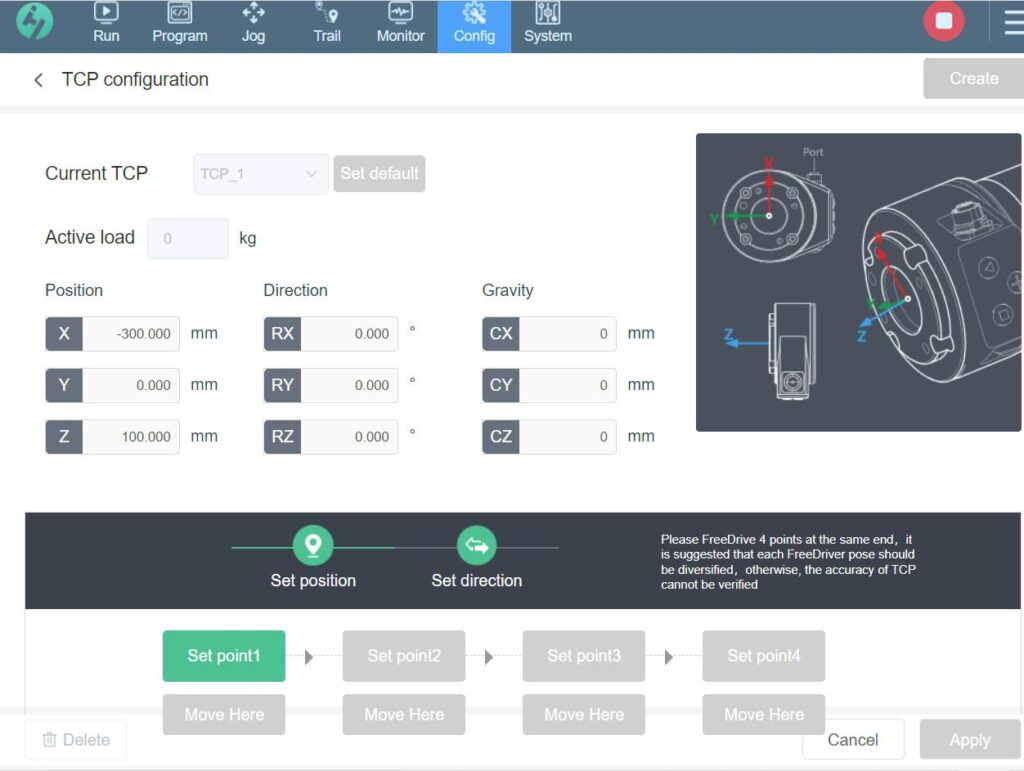
Tool Center Point (TCP) Setup:
- Define tool coordinates with X, Y, Z positions and RX, RY, RZ orientations for customized tool movement paths.
- Payload and Center of Gravity Adjustments: Balance payload distribution by inputting precise weight and center of gravity information, improving stability.
Tool Center Point (TCP) and Payload Configuration
Setting up the TCP accurately is essential for tool manipulation tasks. Users can create new TCPs, specify tool positions, and adjust payload settings to optimize the cobot’s performance.
| TCP Configuration Table | |
|---|---|
| Setting | Details |
| New TCP | Configure a new TCP by defining X, Y, Z, RX, RY, RZ positions |
| Set Position | Use four-point method to set TCP origin |
| Center of Gravity | Define the load’s center of gravity for balanced operation |
Running and Monitoring Operations
Operating the Elfin cobots involves a structured process to ensure stability and safety:
Initialization and Startup
Upon login, users must power on and enable the robot. Joint brakes are released gradually to allow safe initialization.
Program Selection and Real-Time Monitoring
Select and run programs with continuous monitoring of I/O states, motion status, and overall robot health.
3D Visualization of Robot Movements
Real-time 3D display helps monitor the robot’s movement and adjust tasks dynamically.
Status Indicators and Alerts
Notifications and indicator lights (red, green, yellow) provide immediate feedback on operational status and any issues that arise.
Management and System Updates
Elfin cobots provide extensive management features for both user accounts and system configurations:
- User and Permission Management: Set roles and permissions for multiple user accounts, protecting access to critical controls.
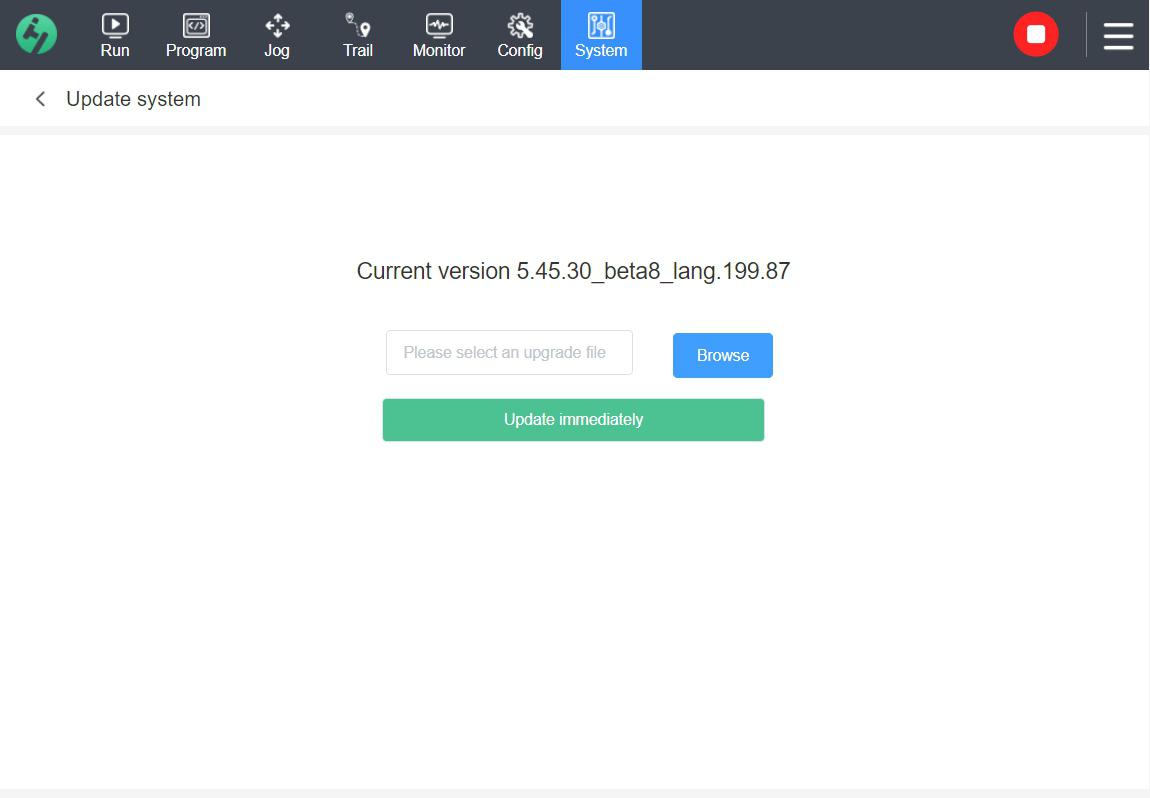
- System Updates and Network Configuration: Regular updates and network setup options (IP configuration) ensure the robot stays current and securely integrated.
- Backup and Restore: Backup options allow users to save configuration settings, making system restoration seamless in the event of changes or updates.
Troubleshooting and Maintenance
Comprehensive troubleshooting and maintenance protocols are included, covering a wide range of scenarios to minimize downtime and maintain performance.
| Function | Description | Notes |
|---|---|---|
| Emergency Stop | Press button to stop all movements immediately | Use only in emergencies |
| Collision Detection | Robot halts if excess force detected | Adjust safety limits or reset manually |
| Singularity Issues | Alerts for potential motion anomalies | Adjust path or check joint limits |
Maintenance Guidelines:
- Ensure all joints and the control cabinet are properly grounded and free from dust.
- Inspect wiring and connections regularly, ensuring cables are undamaged and secure.
- Replace worn parts only with certified replacements from Han’s Robot to maintain safety standards.
Diagram
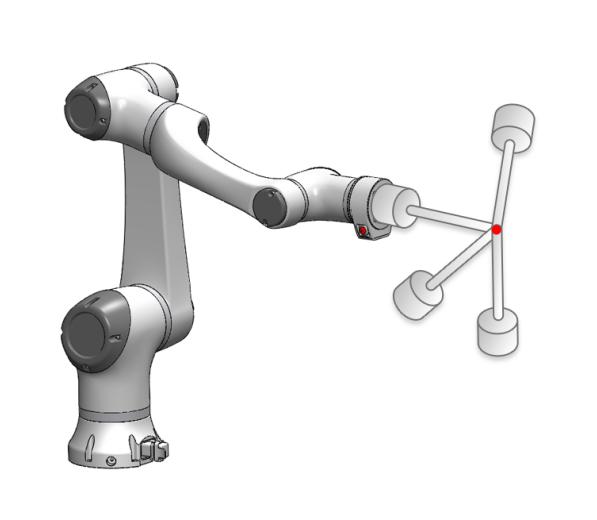
According to the Han’s Robot Product Selection Guide, Han’s collaborative robots are primarily used in the following fields and applications:
Industrial Automation:
– Assembly: Used in production lines for assembly tasks, improving precision and efficiency.
– Welding: Suitable for various welding tasks, including spot welding and arc welding.
– Grinding and Polishing: Applied in surface treatment tasks for metals, plastics, etc., achieving high-precision polishing and grinding.
– Spray Coating: Used in surface coating operations to ensure a uniform coating quality.
Logistics:
– Material Handling: Useful for handling, palletizing, and other logistics operations in warehouses and distribution centers, especially for heavy loads.
– Loading and Unloading: Assists in loading and unloading machines and production equipment, reducing manual labor and enhancing safety and efficiency.
Medical Field:
– Medical Assistance: Collaborative robots can assist in medical environments with tasks like surgery assistance and drug dispensing.
– Rehabilitation Training: Helps patients perform rehabilitation exercises with precision and safety.
Education:
– Robotics Education and Research: Suitable for universities and research institutions for robotics research and educational training.
Hazardous Environment Operations:
– Explosive Environments: The Elfin-Ex explosion-proof collaborative robots are certified for explosion protection, allowing them to operate in environments with explosive gases and combustible dust, making them ideal for high-risk industries like petrochemicals and mining, reducing risks to human operators.
These applications demonstrate Han’s collaborative robots’ versatility and adaptability across industrial, logistics, medical, educational, and hazardous environments, meeting diverse needs for automation and intelligent operations across various sectors.
Frequently Customer Enquiry
Most frequent questions and answers about the Collaborative Robot
What applications are most suitable for the Elfin series collaborative robots?
Elfin series collaborative robots are designed for a variety of applications, including assembly, welding, grinding and polishing, spray coating, material handling, and loading/unloading in automated production environments.
What safety standards does the Elfin robot comply with?
The Elfin robot follows EN ISO 13849-1:2008 standards and adopts a D performance rating (Pld) for safety, ensuring high levels of protection through built-in safety devices and I/O safety features for connections to other machines and protective devices.
How does the Elfin collaborative robot handle path memory for complex movements like grinding
The Elfin robot supports path memory functionality, allowing users to manually guide it along a path. After the first pass, the robot can automatically repeat the path for consistent and precise movement in tasks like grinding and polishing.
Is the Elfin robot compatible with different end tools for applications such as polishing?
Yes, the Elfin robot’s arm can be equipped with various end effectors, such as angle grinders, belt grinders, and specialized polishing tools, providing versatility for tasks requiring different tool attachments.
What are the main features of the Elfin robot that support its collaborative nature
The Elfin robot features a unique double-joint module, which enhances flexibility and minimizes operational constraints. Additionally, it has 10 advanced security configurations, enabling safe collaboration with human operators without the need for extensive safety barriers.
What is the load capacity of the Elfin collaborative robots?
The load capacity varies by model. For example, the Elfin E05 can handle up to 5 kg, while heavier models like the Elfin E15 can carry up to 15 kg, accommodating diverse industrial requirements.
Can Elfin robots be used for rehabilitation and other medical assistance applications?
Yes, Elfin robots are suitable for medical assistance, including rehabilitation exercises, due to their precise control, safety features, and smooth, repetitive motion capabilities.
Is there a provision for using the Elfin robot in educational and research settings?
Yes, the Elfin collaborative robot is suitable for educational and research environments. Due to its flexible programming options, modular design, and ease of use, it is an excellent tool for training students and researchers in robotics, automation, and industrial applications. The robot’s graphical programming interface is particularly beneficial in these settings, as it allows users to set up complex tasks without extensive coding, making it accessible for students and professionals who may be new to robotics.
Additionally, the Elfin robot’s compatibility with multiple communication protocols (like TCP/IP and ModbusTCP) and optional support for Profinet and Ethernet/IP makes it adaptable for various research projects that require integration with other systems. With features such as collision detection and collaborative operation, the Elfin robot can safely operate in a classroom or lab environment, allowing users to experiment and learn about industrial robotics safely and effectively.
Get A Quote Now!
We’d love to hear from you! Send us a message using the form below, or email us.